Commercial model
See pricing details
No public list price (contact sales)
Height
110–145 cm
Weight
60 kg
Battery
4–5h (1 battery) / 8–10h (2 batteries)
Speed
3.6 km/h
Payload
3 kg
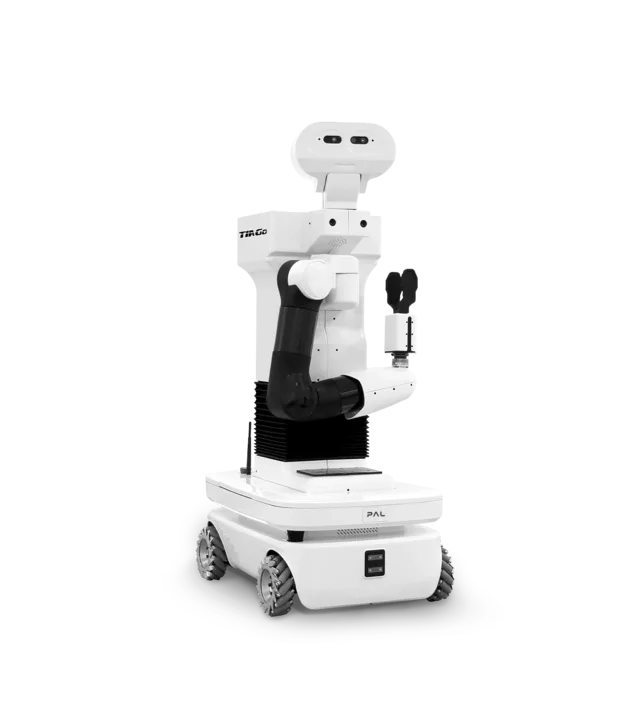
TIAGo (Take It And Go) is a modular mobile manipulator robot developed by PAL Robotics in Barcelona. It combines perception, navigation, manipulation, and human-robot interaction in a customizable platform used by over 40 collaborative research projects across 27 countries. TIAGo features a telescoping torso (110–145 cm height), optional 7 DoF arms with Series Elastic Actuators for safe compliant control, and interchangeable end-effectors including a parallel gripper and the Hey5 anthropomorphic hand. Fully ROS-based with open-source simulation, it supports mapping, autonomous navigation, pick-and-place, grasping, speech recognition, multi-language text-to-speech, and telepresence. Available in configurations from no arms to dual arms.
Listed price
See pricing details
No public list price (contact sales)
Release window
Jan 1, 2015
Current status
Active
PAL Robotics
Last verified
May 25, 2026
Share this robot
Open a plain share composer on X or Bluesky for this robot profile.
Technical overview
A fast read on the mechanical profile, sensing package, and listed platform details for TIAGo.
Height
110–145 cm
Weight
60 kg
Dimensions
ø 54cm footprint, 12 DoF base config (up to 50+ with Hey5 hand)
Battery Life
4–5h (1 battery) / 8–10h (2 batteries)
Charging Time
Not disclosed
Max Speed
3.6 km/h
Payload
3 kg
Operational profile
Capabilities
12
Connectivity
2
Key capabilities
Listed platforms & ecosystem
Explore further
Benchmark set
Shortcuts to the closest alternatives in the current ui44 set.
Research
TIAGo Pro
PAL Robotics
See pricing details
Research
REEM-C
PAL Robotics
See pricing details
Research
ASIMO
Honda
See pricing details
Research
TALOS
PAL Robotics
See pricing details
Coverage
Reporting and explainers linked to TIAGo.
The TIAGo is a Research robot built by PAL Robotics. TIAGo (Take It And Go) is a modular mobile manipulator robot developed by PAL Robotics in Barcelona. It combines perception, navigation, manipulation, and human-robot interaction in a customizable platform used by over 40 collaborative research projects across 27 countries. TIAGo features a telescoping torso (110–145 cm height), optional 7 DoF arms with Series Elastic Actuators for safe compliant control, and interchangeable end-effectors including a parallel gripper and the Hey5 anthropomorphic hand. Fully ROS-based with open-source simulation, it supports mapping, autonomous navigation, pick-and-place, grasping, speech recognition, multi-language text-to-speech, and telepresence. Available in configurations from no arms to dual arms.
No public list price (contact sales) See all PAL Robotics robots on the PAL Robotics page.
Detailed specifications for the TIAGo
Height
110–145cm (telescoping torso)The listed height is 110–145cm (telescoping torso). Height alone does not establish working reach or clearance under furniture; check the documented operating configuration and required space.
Weight
60 kg in the current documented hardware overview; modular arm/end-effector configurations may varyThe listed weight is 60 kg in the current documented hardware overview; modular arm/end-effector configurations may vary. Weight alone does not establish locomotion, stability or safety around people. Check handling requirements and the model’s documented operating limits.
Dimensions
ø 54cm footprint, 12 DoF base config (up to 50+ with Hey5 hand)The overall dimensions of ø 54cm footprint, 12 DoF base config (up to 50+ with Hey5 hand) are a recorded size entry. Check which axes and configuration it covers: a height-only entry does not establish width, depth or passage fit. Planning clearance also requires the operating envelope, turning space, attachments and documented margins.
Battery Life
4–5h (1 battery) / 8–10h (2 batteries)This is the recorded runtime entry. Test conditions and independent verification are not established by this field. Confirm workload, operating mode and environmental conditions before comparing runtimes.
Maximum Speed
3.6 km/hThe recorded maximum-speed entry is 3.6 km/h. It does not establish sustained travel speed, terrain handling, or safe speed around people. Check the source's gait, operating mode, surface and load conditions before planning movement through a shared space.
Payload Capacity
3 kg arm payload (without end-effector)The recorded payload entry is 3 kg arm payload (without end-effector). A load figure alone does not establish which objects the robot can grasp, lift or carry. Confirm whether the limit applies to one arm, two arms or a mounted load, and check reach, posture and motion conditions in model-specific documentation.
AI Platform
ROS-based autonomy with MoveIt!, SLAM navigation, whole body control, facial and speech recognitionRead this recorded AI entry alongside the model description and source notes for announcement or deployment context. A platform name alone does not establish implemented features, autonomy, or performance.
The profile lists the sensor descriptions below. These entries do not establish physical sensor counts, sensor fusion, redundancy, or performance.
Consult the linked profile sources for hardware configuration and tested behavior. A technology label alone does not verify an operating capability.
Explore sensor technologies: components glossary · full components directory
Research robots serve as platforms for advancing robotics science and engineering. They enable researchers to test theories about locomotion, manipulation, perception, and human-robot interaction in controlled and real-world environments.
The TIAGo record lists 12 capabilities. Keep any announcement or demonstration qualifiers attached to these entries; the count alone does not establish practical performance.
These are the capabilities listed in the profile. Hardware configuration and demonstrated performance should be checked against the linked sources.
These are the platforms, communities, or ecosystem relationships listed in the profile. A listed name or protocol alone does not confirm home-device interoperability or automation support.
12
Capabilities
AI
ROS-based autonomy with…
General context · confirm model-specific support
Autonomous navigation concerns movement toward a goal within defined operating conditions. Useful evidence includes the mapped area, localization method, obstacle tests, permitted surfaces and recovery process when a route is blocked. Establish when a person must intervene and whether remote assistance is involved; the label alone does not identify SLAM, particular sensors or an unattended operating envelope.
The TIAGo profile lists the following communication and voice-system descriptions.
The TIAGo by PAL Robotics has the following technology descriptions in its profile. The physical platform features a height of 110–145cm (telescoping torso), a weight of 60 kg in the current documented hardware overview; modular arm/end-effector configurations may vary, a top speed of 3.6 km/h, providing the foundation on which this technology stack operates.
The profile lists RGB-D Camera, Force/Torque Sensor (wrist), Laser Range Finder, Sonar Sensors, IMU, Two Microphone Arrays, Touchscreen (optional), Fingertip Sensors (optional). Hardware quantities, integration, and tested behavior require separate source evidence.
Recorded AI description: ROS-based autonomy with MoveIt!, SLAM navigation, whole body control, facial and speech recognition
Research robots are acquired by universities, government labs, and corporate R&D departments. They serve as experimental platforms for developing new algorithms, testing locomotion strategies, and advancing the field of robotics. Some are also used for educational purposes.
Open-source software compatibility (ROS/ROS 2), sensor modularity, programmability, available SDK/API quality, community support, and published research papers using the platform are key factors. Documentation quality and the ability to modify both hardware and software are essential for research use.
Listed pricing
The TIAGo is listed as Active. This status alone does not confirm public purchase availability or operational reliability. Contact PAL Robotics for current access options and any purchase or participation requirements.
Recorded features and considerations to assess
The TIAGo record lists 12 capabilities. Review their qualifiers and supporting evidence for the tasks you need. The number of entries does not establish workflow coverage, reliability, or the ability to replace other robots.
The battery-life entry is 4–5h (1 battery) / 8–10h (2 batteries). Check the source conditions and operating mode before using this figure to plan a session. It does not establish task completion, area coverage, or continuous-use runtime.
At 60 kg in the current documented hardware overview; modular arm/end-effector configurations may vary, the TIAGo is a substantial piece of equipment. Check documented floor-load limits, transport and handling requirements, and operating precautions. Weight alone does not establish stability, robustness or safety around people.
No public list price (contact sales)
Note: This strengths and trade-offs assessment is based on the TIAGo's documented specifications as tracked in the ui44 database. Real-world performance depends on deployment conditions, firmware maturity, and environmental factors. For the most current information, check the PAL Robotics manufacturer page or visit the official source. Use the comparison tool to evaluate these trade-offs against competing robots in the same category.
Understanding the engineering behind this category
Research robots serve a fundamentally different purpose than commercial or consumer models. They are platforms for discovery — enabling scientists and engineers to test theories, develop algorithms, and push the boundaries of what robots can do. The technology in research robots prioritizes openness, flexibility, and access to raw data over consumer-friendly packaging or commercial reliability. Understanding this distinction is important for anyone considering a research robot platform.
Research robots typically expose their navigation systems at a much lower level than commercial products. Researchers can access raw sensor data, modify SLAM algorithms, implement custom path planners, and test novel navigation approaches. ROS (Robot Operating System) and ROS 2 compatibility is standard, providing a common framework for sharing navigation modules across the research community. This openness enables rapid iteration — a researcher can swap between different SLAM implementations, test new obstacle avoidance strategies, or develop entirely novel navigation paradigms without being locked into a vendor's proprietary stack.
Research robots serve as physical testbeds for AI algorithms that may eventually appear in commercial products years later. Reinforcement learning, imitation learning, few-shot task learning, and human-robot interaction studies all require robot platforms that can execute AI-generated commands in the physical world. The gap between simulation (where training is cheap and fast) and reality (where physics is unforgiving) makes physical robot platforms essential for validating AI approaches. Research robots must support rapid deployment of new AI models without extensive integration work.
Research platforms prioritize sensor modularity and data access. Standard mounting interfaces allow researchers to attach custom sensors alongside built-in ones. Raw sensor data streams (not just processed results) are accessible for developing novel perception algorithms. Precise time-stamping and synchronization across sensor streams enable accurate multi-modal fusion research. Many research robots include more sensors than strictly necessary for any single application, providing researchers with rich datasets for developing and testing new algorithms.
Research robots balance operational runtime with practical lab use. Sessions of one to four hours are typical, with quick charging between experiments. Some research setups use tethered power for long-running experiments where battery limitations would interrupt data collection. Power monitoring and logging capabilities help researchers understand the energy costs of different behaviors and algorithms — important for developing efficient approaches that will eventually run on battery-constrained commercial systems.
Research environments present unique safety challenges because robots are constantly being programmed with untested behaviors. Hardware safety limits (joint speed caps, force limits, emergency stops) must be robust regardless of software commands. Safety-rated monitored stop and speed monitoring ensure the robot cannot exceed safe operating parameters even when running experimental code. Collaborative operation standards apply when researchers work alongside the robot during experiments. Many labs implement layered safety with physical barriers for high-speed testing and open-area operation restricted to validated, lower-risk behaviors.
Research robot platforms are becoming more accessible and capable. Cloud robotics enables remote experiment execution and shared datasets. Digital twins and high-fidelity simulators reduce the need for physical hardware time while improving sim-to-real transfer. Standardized benchmarks and open datasets enable fair comparison of results across labs. The democratization of robotics research — through lower-cost platforms, open-source software, and cloud infrastructure — is expanding who can contribute to advancing the field.
These are category-level technology examples; they do not establish the capabilities of the TIAGo. For its recorded hardware details, see the sensor analysis and connectivity sections above. Check model-specific documentation from PAL Robotics for supported behavior, or use the components glossary to look up terminology.
How this robot compares in the research landscape
No public list price (contact sales)
The TIAGo is listed as Active. This status alone does not confirm public purchase availability or operational reliability. Contact PAL Robotics for current access options and any purchase or participation requirements.
Side-by-side specs, capability overlap analysis, and key differentiators.
For the full picture of PAL Robotics's portfolio and market strategy, visit the PAL Robotics manufacturer page.
What the public profile tells you, and what still needs direct vendor confirmation
From a buying and rollout perspective, the TIAGo should be read as a research platform aimed at labs and development teams validating robotics workflows. ui44 currently tracks 12 capability signals and a last verification date of 2026-05-25. That mix gives buyers a useful first-pass picture, but it is still only the public layer of due diligence, especially when procurement, uptime, and support commitments are decided directly with PAL Robotics.
Commercial model
See pricing details
No public list price (contact sales)
Integration posture
2 connectivity options
The profile lists Wi-Fi, Ethernet. These labels do not establish APIs, fleet-management features, or workflow integration. These are the platforms, communities, or ecosystem relationships listed in the profile. A listed name or protocol alone does not confirm home-device interoperability or automation support.Recorded AI description: ROS-based autonomy with MoveIt!, SLAM navigation, whole body control, facial and speech recognition
Spec disclosure
6/7 core specs public
ui44 currently has 6 of 7 core physical and operating specs filled in for this model, leaving 1 gap that matter for deployment planning. Missing runtime, charge, speed, or payload details can materially change staffing and site-readiness assumptions.
The current profile is detailed enough to support early comparison work, shortlist creation, and cross-checking against other research robots. It is still worth validating the final deployment package, because integration services, support coverage, software entitlements, and site-preparation requirements often sit outside the raw hardware spec sheet.
If you want a faster apples-to-apples read, compare the TIAGo against nearby alternatives in ui44's compare view, then cross-check the underlying AI, sensor, and subsystem terms in the components glossary. For manufacturer-level context, the PAL Robotics profile helps anchor this robot inside the wider product lineup.
Practical guide from day one through years of ownership
Research robot setup combines hardware assembly with software environment configuration. Unpack and assemble the platform following the manufacturer's documentation. Install the development framework — typically ROS or ROS 2 — and verify sensor connectivity. Calibrate all sensors using the manufacturer's tools and procedures. Set up the simulation environment (Gazebo, Isaac Sim, or equivalent) alongside the physical platform for parallel development. Establish version control for your experiment code and configuration. Document the initial calibration values and system state as your baseline for future reference. Plan network and computing infrastructure to handle the data rates your sensors will generate.
Research robots need maintenance that preserves the precision required for valid experimental results. Regularly verify sensor calibration — drift in camera intrinsics or IMU biases can invalidate experiment data. Maintain clean workspace conditions to protect optical sensors. Document any hardware modifications or maintenance performed, as these can affect experimental reproducibility. Update software dependencies carefully, documenting versions used for each experiment. Joint and actuator wear in research robots that perform repetitive tasks should be monitored and factored into experimental design.
Research robot software updates require careful management to maintain experiment reproducibility. Document the exact software versions used for each experiment. Test updates in a separate environment before applying to your experiment platform. Contribute bug fixes and improvements back to the community when using open-source frameworks. Be aware that ROS and other framework updates may require code changes in your custom packages — budget time for integration testing after major framework updates.
Research robots often have longer productive lives than commercial products because they can be upgraded and repurposed. Extend your investment by maintaining clean mechanical and electrical systems, documenting all modifications for future lab members, and keeping spare parts for common wear items. When specific components become obsolete, community forums and lab networks can be valuable sources for replacements. Consider the platform's modularity when planning future research directions — a platform that can accept new sensors and actuators adapts to evolving research questions.
Find product and source links on the PAL Robotics page on ui44 or open PAL Robotics's official source. Use model-specific manufacturer documentation for setup, cleaning, and service instructions.
The TIAGo record brings together the listed specifications and attributed claims. Consult the model description and source notes to distinguish manufacturer announcements, reported information, and unknowns. A source link or review date does not establish independent testing or manufacturer confirmation of every claim. Record last checked: 2026-05-25. Official source: PAL Robotics official source. If you find outdated or incorrect information, please let us know — accuracy is our top priority.
See how the TIAGo stacks up — compare specs, browse the research category, or search the full database.