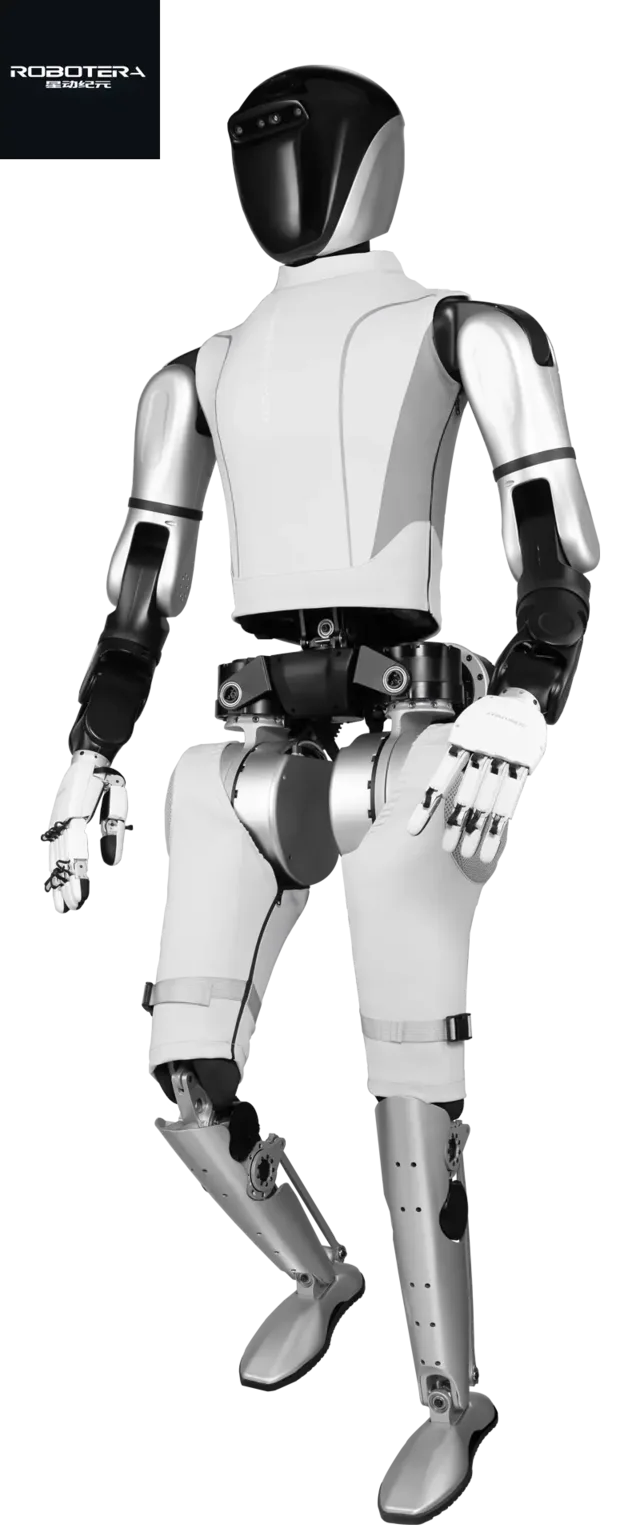
RobotEra STAR1
STAR1 is a humanoid robot from RobotEra (星动纪元). A 2025 company brochure hosted by the World Robot Conference identifies STAR1 as having 55 total degrees of freedom, including 12 across its legs, 7 per arm and 12 active degrees of freedom in each XHAND1 hand. The brochure lists maximum joint torque of 400 Nm and rotational speed of 25 rad/s, and describes a 3.6 m/s outdoor run as a world record for electrically driven humanoids. It also attributes tool-use manipulation examples to STAR1 working with RobotEra's ERA-42 model. Its separate ERA-42 section claims learning from limited data; this is a historical company claim about the model, not independently verified STAR1 task reliability. The brochure does not establish current availability or reliable deployment in homes.