Commercial model
See pricing details
Not officially disclosed; official Matrix Robotics page describes an Early Access Program for select industry partners, with initial pilot deployments expected in mid-2026.
Speed
2.5 km/h
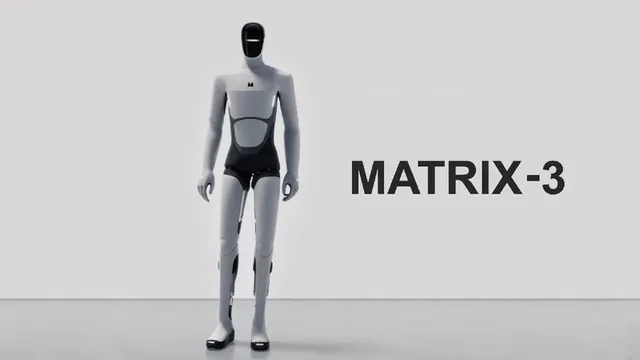
MATRIX-3 is the third-generation flagship humanoid from Matrix Robotics, launched January 10, 2026. It introduces three core innovations: 3D woven biomimetic skin with distributed tactile sensors capable of detecting forces as low as 0.1 N, 27-DOF cable-driven dexterous hands (the "Intuitive Hand") that closely mirror human anatomy for tool use and delicate manipulation, and a proprietary cognitive core enabling zero-shot generalization — the ability to perform unfamiliar tasks from natural-language instructions without task-specific training. Full-body motion is powered by proprietary linear actuators and trained on human motion-capture datasets for natural gait. Matrix Robotics targets commercial services, manufacturing, logistics, medical assistance, and eventually home environments. An Early Access Program for industry partners is open, with pilot deployments expected to begin in mid-2026. Height, weight, battery life, and pricing have not been officially disclosed. The CGI-heavy launch presentation attracted some industry skepticism about whether physical capabilities match the marketing.
Listed price
See pricing details
Not officially disclosed; official Matrix Robotics page describes an Early Access Program for select industry partners, with initial pilot deployments expected in mid-2026.
Release window
Jan 10, 2026
Current status
Development
Matrix Robotics
Last verified
Jul 6, 2026
Share this robot
Open a plain share composer on X or Bluesky for this robot profile.
Technical overview
A fast read on the mechanical profile, sensing package, and listed platform details for MATRIX-3.
Height
Not officially disclosed; Humanoid.Guide estimates ~160–180 cm but marks the profile not verified
Weight
Not officially disclosed
Battery Life
Not officially disclosed
Charging Time
Not officially disclosed
Max Speed
2.5 km/h
Operational profile
Capabilities
6
Connectivity
0
Key capabilities
Explore further
Benchmark set
Shortcuts to the closest alternatives in the current ui44 set.
Humanoid
Astribot T1
Astribot (Stardust Intelligence)
See pricing details
Humanoid
Bumi
Noetix Robotics
See pricing details
Humanoid
Booster T1
Booster Robotics
$29,800
Humanoid
Expedition A3
AGIBOT
See pricing details
Coverage
Reporting and explainers linked to MATRIX-3.
The MATRIX-3 is a Humanoid robot built by Matrix Robotics. MATRIX-3 is the third-generation flagship humanoid from Matrix Robotics, launched January 10, 2026. It introduces three core innovations: 3D woven biomimetic skin with distributed tactile sensors capable of detecting forces as low as 0.1 N, 27-DOF cable-driven dexterous hands (the "Intuitive Hand") that closely mirror human anatomy for tool use and delicate manipulation, and a proprietary cognitive core enabling zero-shot generalization — the ability to perform unfamiliar tasks from natural-language instructions without task-specific training. Full-body motion is powered by proprietary linear actuators and trained on human motion-capture datasets for natural gait. Matrix Robotics targets commercial services, manufacturing, logistics, medical assistance, and eventually home environments. An Early Access Program for industry partners is open, with pilot deployments expected to begin in mid-2026. Height, weight, battery life, and pricing have not been officially disclosed. The CGI-heavy launch presentation attracted some industry skepticism about whether physical capabilities match the marketing.
Not officially disclosed; official Matrix Robotics page describes an Early Access Program for select industry partners, with initial pilot deployments expected in mid-2026. See all Matrix Robotics robots on the Matrix Robotics page.
Detailed specifications for the MATRIX-3
Maximum Speed
2.5 km/h (Humanoid.Guide; not manufacturer-published, profile not verified)The recorded maximum-speed entry is 2.5 km/h (Humanoid.Guide; not manufacturer-published, profile not verified). It does not establish sustained travel speed, terrain handling, or safe speed around people. Check the source's gait, operating mode, surface and load conditions before planning movement through a shared space.
Read this recorded AI entry alongside the model description and source notes for announcement or deployment context. A platform name alone does not establish implemented features, autonomy, or performance.
The profile lists the sensor descriptions below. These entries do not establish physical sensor counts, sensor fusion, redundancy, or performance.
Consult the linked profile sources for hardware configuration and tested behavior. A technology label alone does not verify an operating capability.
Explore sensor technologies: components glossary · full components directory
The Humanoid category includes different mobility configurations. Check the specific model’s documented locomotion, doorway clearances and operating surfaces. Category membership alone does not establish stair capability or suitability for an unmodified workspace.
The MATRIX-3 record lists 6 capabilities. Keep any announcement or demonstration qualifiers attached to these entries; the count alone does not establish practical performance.
These are the capabilities listed in the profile. Hardware configuration and demonstrated performance should be checked against the linked sources.
Compatibility and ecosystem details are not specified in the available profile.
6
Capabilities
AI
Proprietary neural network…
The MATRIX-3 by Matrix Robotics has the following technology descriptions in its profile. The physical platform features a top speed of 2.5 km/h (Humanoid.Guide; not manufacturer-published, profile not verified), providing the foundation on which this technology stack operates.
The profile lists High-sensitivity tactile sensor array (0.1 N minimum detection), 3D woven biomimetic skin with distributed sensing network, Spatial perception foundation model (vision). Hardware quantities, integration, and tested behavior require separate source evidence.
Humanoid robots are typically targeted at enterprise customers, research institutions, and forward-thinking businesses looking to automate tasks that require human-like form and dexterity. While some models are approaching consumer pricing, the majority remain in the commercial and industrial space.
When evaluating a humanoid robot, payload capacity, degrees of freedom, and manipulation dexterity are critical factors. Battery life and charging time determine operational uptime. The AI platform determines how well the robot can adapt to new tasks and environments. Consider whether the robot needs to work alongside humans (requiring safety certifications) or will operate independently.
Listed pricing
The MATRIX-3 is listed as Development, indicating active development in the catalog. Specifications and release plans may change. Check Matrix Robotics's current documentation for access options and release updates.
Recorded features and considerations to assess
The MATRIX-3 record lists 6 capabilities. Review their qualifiers and supporting evidence for the tasks you need. The number of entries does not establish workflow coverage, reliability, or the ability to replace other robots.
Not officially disclosed; official Matrix Robotics page describes an Early Access Program for select industry partners, with initial pilot deployments expected in mid-2026.
The MATRIX-3 is listed as Development, indicating active development in the catalog. Specifications and release plans may change. Check Matrix Robotics's current documentation for access options and release updates.
Compatibility and ecosystem details are not specified in the profile for the MATRIX-3. Confirm supported platforms, device-control functions, and deployment requirements in product documentation before relying on an integration.
Note: This strengths and trade-offs assessment is based on the MATRIX-3's documented specifications as tracked in the ui44 database. Real-world performance depends on deployment conditions, firmware maturity, and environmental factors. For the most current information, check the Matrix Robotics manufacturer page or visit the official source. Use the comparison tool to evaluate these trade-offs against competing robots in the same category.
Understanding the engineering behind this category
Humanoid robots represent one of the most technically ambitious categories in robotics. Building a machine that walks, balances, manipulates objects, and interacts naturally with humans requires breakthroughs across multiple engineering disciplines simultaneously. Understanding the technology behind humanoid robots helps buyers and enthusiasts appreciate both the capabilities and limitations of current systems.
Humanoid robots navigate using a combination of visual SLAM (Simultaneous Localization and Mapping), depth sensing, and inertial measurement. Unlike wheeled robots that simply avoid obstacles, humanoids must plan footstep placement, maintain dynamic balance on uneven surfaces, and anticipate terrain changes. Advanced systems use predictive models to plan several steps ahead, similar to how humans unconsciously adjust their gait when approaching stairs or rough ground. The computational requirements for real-time bipedal navigation are substantial, often requiring dedicated motion-planning processors separate from the main AI system.
Artificial intelligence in humanoid robots serves multiple roles: high-level task planning (understanding what needs to be done), perception (recognizing objects, people, and environments), manipulation planning (figuring out how to grasp and move objects), and social interaction (understanding speech, gestures, and context). Modern humanoids increasingly use large language models and vision-language models for task understanding, allowing them to interpret natural language instructions and generalize to new tasks without explicit programming for each scenario.
The sensor suite in a humanoid robot must provide comprehensive environmental awareness while maintaining real-time processing speeds. Sensor fusion algorithms combine data from cameras, LiDAR, depth sensors, force/torque sensors, and IMUs to create a unified model of the robot's surroundings. This multi-modal perception is critical because no single sensor type works perfectly in all conditions — cameras struggle in darkness, LiDAR cannot distinguish materials, and touch sensors only detect what the robot physically contacts. By combining these inputs, the robot achieves more robust and reliable perception than any individual sensor could provide.
Battery technology is one of the primary limiting factors for humanoid robots. Bipedal locomotion is inherently energy-intensive — maintaining balance requires constant motor activity even when standing still. Current lithium-ion battery packs typically provide two to four hours of active operation, with charging times that can match or exceed operational time. Research into more efficient actuators, energy-harvesting techniques, and advanced battery chemistries aims to extend operational windows. Some commercial deployments address this limitation through battery-swap systems or scheduled charging rotations.
Safety in humanoid robotics is paramount because these robots operate in close proximity to humans. Design approaches include compliant actuators that absorb impact forces, real-time collision prediction systems, force-limited joints that automatically reduce power when unexpected contact occurs, and emergency stop mechanisms accessible to nearby humans. International safety standards like ISO 13482 for personal care robots provide frameworks for evaluating safety, but the field is still developing standards specific to general-purpose humanoid systems. Buyers should inquire about safety testing, certifications, and the robot's behavior in failure modes.
The humanoid robotics field is advancing rapidly on multiple fronts. Improvements in foundation models are enabling more generalizable intelligence. New actuator designs are making robots lighter and more efficient. Manufacturing scale is driving down costs. Over the next several years, expect humanoid robots to transition from controlled industrial environments to more varied commercial and eventually residential settings. The convergence of better AI, cheaper hardware, and proven deployment experience will accelerate adoption across industries.
These are category-level technology examples; they do not establish the capabilities of the MATRIX-3. For its recorded hardware details, see the sensor analysis and connectivity sections above. Check model-specific documentation from Matrix Robotics for supported behavior, or use the components glossary to look up terminology.
How this robot compares in the humanoid landscape
Not officially disclosed; official Matrix Robotics page describes an Early Access Program for select industry partners, with initial pilot deployments expected in mid-2026.
The MATRIX-3 is listed as Development, indicating active development in the catalog. Specifications and release plans may change. Check Matrix Robotics's current documentation for access options and release updates.
Side-by-side specs, capability overlap analysis, and key differentiators.
For the full picture of Matrix Robotics's portfolio and market strategy, visit the Matrix Robotics manufacturer page.
What the public profile tells you, and what still needs direct vendor confirmation
From a buying and rollout perspective, the MATRIX-3 should be read as a humanoid platform aimed at human-scale workplaces and pilot automation programs. ui44 currently tracks 6 capability signals and a last verification date of 2026-07-06. That mix gives buyers a useful first-pass picture, but it is still only the public layer of due diligence, especially when procurement, uptime, and support commitments are decided directly with Matrix Robotics.
Commercial model
See pricing details
Not officially disclosed; official Matrix Robotics page describes an Early Access Program for select industry partners, with initial pilot deployments expected in mid-2026.
Integration posture
Integration details thin
The page does not list any connectivity standards, so procurement teams should verify network requirements, remote management options, and how the robot fits into existing software or facility infrastructure.Recorded AI description: Proprietary neural network architecture by Matrix Super Intelligence with zero-shot generalization; visual-tactile feedback loop for material, shape, and grip-stability assessment
Spec disclosure
1/7 core specs public
ui44 currently has 1 of 7 core physical and operating specs filled in for this model, leaving 6 gaps that matter for deployment planning. Missing runtime, charge, speed, or payload details can materially change staffing and site-readiness assumptions.
The current profile is useful for scouting, but it still leaves meaningful operational unknowns. If this robot is heading toward a pilot or purchase discussion, the next step should be a structured vendor Q&A that fills the remaining runtime, charging, payload, safety, or integration blanks before anyone builds ROI assumptions around it.
If you want a faster apples-to-apples read, compare the MATRIX-3 against nearby alternatives in ui44's compare view, then cross-check the underlying AI, sensor, and subsystem terms in the components glossary. For manufacturer-level context, the Matrix Robotics profile helps anchor this robot inside the wider product lineup.
Practical guide from day one through years of ownership
Setting up a humanoid robot is substantially more involved than plug-and-play consumer devices. Expect a professional installation or guided setup process that includes physical unpacking and assembly (if shipped disassembled), initial calibration of joints and sensors, environment mapping and safety zone definition, network and cloud service configuration, and application-specific programming or task teaching. Plan for several hours to a full day of setup time, and budget for potential integration consulting if the robot needs to connect with existing systems. The manufacturer or a certified integrator should provide training on safe operation, emergency procedures, and basic troubleshooting.
Humanoid robots require regular maintenance to ensure safe and reliable operation. Monthly maintenance typically includes visual inspection of joints and actuators for wear, sensor cleaning (especially cameras and LiDAR), firmware and software updates, battery health checks, and calibration verification. Quarterly maintenance may include more thorough mechanical inspection, lubrication of moving parts, and performance benchmarking to detect gradual degradation. Keep a maintenance log and follow the manufacturer's recommended schedule precisely — humanoid robots are complex systems where small issues can cascade if not addressed promptly.
Humanoid robot software is evolving rapidly, and regular updates can significantly improve performance, add new capabilities, and patch security vulnerabilities. Most manufacturers provide over-the-air updates, but enterprise deployments may require staging and testing updates before rolling them out. Evaluate the manufacturer's update track record — frequent, well-documented updates indicate active development and long-term commitment. Be aware that major software updates may require recalibration or retraining of custom behaviors.
To maximize the useful life of a humanoid robot, avoid operating beyond specified payload limits, maintain a controlled environment (temperature, humidity), keep sensors clean and unobstructed, and address any unusual sounds or behaviors promptly. Battery longevity is improved by avoiding deep discharges and extreme temperatures during charging. Investing in a service contract with the manufacturer or a certified partner provides access to replacement parts and expertise that can extend the robot's productive life significantly beyond the standard warranty period.
Find product and source links on the Matrix Robotics page on ui44 or open Matrix Robotics's official source. Use model-specific manufacturer documentation for setup, cleaning, and service instructions.
The MATRIX-3 record brings together the listed specifications and attributed claims. Consult the model description and source notes to distinguish manufacturer announcements, reported information, and unknowns. A source link or review date does not establish independent testing or manufacturer confirmation of every claim. Record last checked: 2026-07-06. Official source: Matrix Robotics official source. If you find outdated or incorrect information, please let us know — accuracy is our top priority.
See how the MATRIX-3 stacks up — compare specs, browse the humanoid category, or search the full database.