Commercial model
See pricing details
Not yet announced; Dynamixel-Q actuators scheduled for commercial release H2 2026
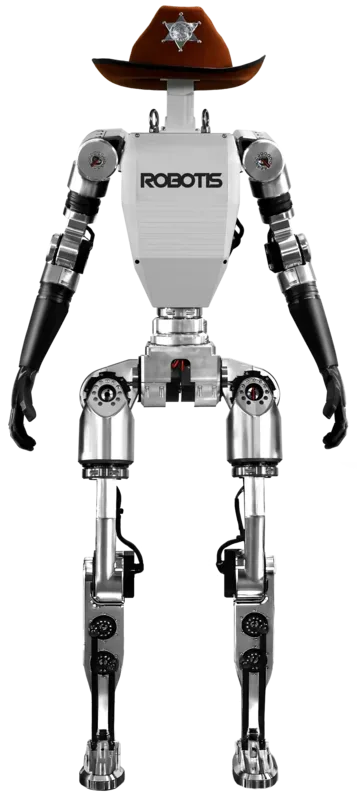
Height
1300 mm
Weight
34 kg
Payload
3 kg
AI Sapiens K0 is a fully open-source humanoid research platform from ROBOTIS, the South Korean actuator manufacturer behind the Dynamixel servo line. Standing 1.3 m tall and weighing 34 kg with 23 degrees of freedom, it is designed as a reproducible baseline for Physical AI research — bridging simulation-trained policies with real hardware deployment. The platform is powered by 23 Dynamixel-Q Quasi-Direct Drive (QDD) actuators (14× QM-060, 9× QM-080) that provide high backdrivability and torque-level control for dynamic balancing and compliant manipulation. K0 supports reinforcement learning training in NVIDIA Isaac Sim and imitation learning via a leader-follower data collection system. ROBOTIS plans to release the complete hardware Bill of Materials, STEP CAD files, source code, simulation assets, and tutorials as open source, enabling researchers to build, modify, and extend the platform without licensing restrictions. The onboard compute features a Cortex-A76/A55 CPU, Mali-G610 GPU, and a 6 TOPS NPU, powered by a 46.8 V 9000 mAh battery.
Listed price
See pricing details
Not yet announced; Dynamixel-Q actuators scheduled for commercial release H2 2026
Release window
Jan 1, 2026
Current status
Development
ROBOTIS
Last verified
Apr 24, 2026
Share this robot
Open a plain share composer on X or Bluesky for this robot profile.
Technical overview
A fast read on the mechanical profile, sensing package, and listed platform details for AI Sapiens K0.
Height
1300 mm
Weight
34 kg
Dimensions
Humanoid form factor; 1300 mm height
Battery Life
Not officially disclosed (46.8 V, 9000 mAh battery)
Charging Time
Not disclosed
Max Speed
Not disclosed
Payload
3 kg
Operational profile
Capabilities
7
Connectivity
5
Key capabilities
Listed platforms & ecosystem
Explore further
Benchmark set
Shortcuts to the closest alternatives in the current ui44 set.
Research
ROBOTIS OP3
ROBOTIS
$13,764
Research
SURENA IV
University of Tehran (CAST)
See pricing details
Research
HOPEJr
Hugging Face LeRobot
$3,000
Research
TIAGo Pro
PAL Robotics
See pricing details
Coverage
Reporting and explainers linked to AI Sapiens K0.
Blog
2026-05-26 · ui44 Team
MolmoAct 2: Open Robot AI for Home Chores?
Blog
2026-05-25 · ui44 Team
Humanoid Robot Actuators: Home Readiness Guide
Blog
2026-05-18 · ui44 Team
Rotaku Domo: What $3,998 Really Includes
Blog
2026-05-13 · ui44 Team
Can AI Coding Agents Build Home Robot Apps?
Blog
2026-05-09 · ui44 Team
Will Self-Driving Car AI Power Home Robots?
The AI Sapiens K0 is a Research robot built by ROBOTIS. AI Sapiens K0 is a fully open-source humanoid research platform from ROBOTIS, the South Korean actuator manufacturer behind the Dynamixel servo line. Standing 1.3 m tall and weighing 34 kg with 23 degrees of freedom, it is designed as a reproducible baseline for Physical AI research — bridging simulation-trained policies with real hardware deployment. The platform is powered by 23 Dynamixel-Q Quasi-Direct Drive (QDD) actuators (14× QM-060, 9× QM-080) that provide high backdrivability and torque-level control for dynamic balancing and compliant manipulation. K0 supports reinforcement learning training in NVIDIA Isaac Sim and imitation learning via a leader-follower data collection system. ROBOTIS plans to release the complete hardware Bill of Materials, STEP CAD files, source code, simulation assets, and tutorials as open source, enabling researchers to build, modify, and extend the platform without licensing restrictions. The onboard compute features a Cortex-A76/A55 CPU, Mali-G610 GPU, and a 6 TOPS NPU, powered by a 46.8 V 9000 mAh battery.
Not yet announced; Dynamixel-Q actuators scheduled for commercial release H2 2026 See all ROBOTIS robots on the ROBOTIS page.
Detailed specifications for the AI Sapiens K0
Height
1300 mm (1.3 m)The listed height is 1300 mm (1.3 m). Height alone does not establish working reach or clearance under furniture; check the documented operating configuration and required space.
Weight
34 kgThe listed weight is 34 kg. Weight alone does not establish locomotion, stability or safety around people. Check handling requirements and the model’s documented operating limits.
Dimensions
Humanoid form factor; 1300 mm heightThe overall dimensions of Humanoid form factor; 1300 mm height are a recorded size entry. Check which axes and configuration it covers: a height-only entry does not establish width, depth or passage fit. Planning clearance also requires the operating envelope, turning space, attachments and documented margins.
Payload Capacity
3 kg max arm payloadThe recorded payload entry is 3 kg max arm payload. A load figure alone does not establish which objects the robot can grasp, lift or carry. Confirm whether the limit applies to one arm, two arms or a mounted load, and check reach, posture and motion conditions in model-specific documentation.
Read this recorded AI entry alongside the model description and source notes for announcement or deployment context. A platform name alone does not establish implemented features, autonomy, or performance.
The profile lists the sensor descriptions below. These entries do not establish physical sensor counts, sensor fusion, redundancy, or performance.
Consult the linked profile sources for hardware configuration and tested behavior. A technology label alone does not verify an operating capability.
Explore sensor technologies: components glossary · full components directory
Research robots serve as platforms for advancing robotics science and engineering. They enable researchers to test theories about locomotion, manipulation, perception, and human-robot interaction in controlled and real-world environments.
The AI Sapiens K0 record lists 7 capabilities. Keep any announcement or demonstration qualifiers attached to these entries; the count alone does not establish practical performance.
These are the capabilities listed in the profile. Hardware configuration and demonstrated performance should be checked against the linked sources.
These are the platforms, communities, or ecosystem relationships listed in the profile. A listed name or protocol alone does not confirm home-device interoperability or automation support.
7
Capabilities
AI
6 TOPS NPU…
The AI Sapiens K0 profile lists the following communication and voice-system descriptions.
The AI Sapiens K0 by ROBOTIS has the following technology descriptions in its profile. The physical platform features a height of 1300 mm (1.3 m), a weight of 34 kg, providing the foundation on which this technology stack operates.
The profile lists IMU (inferred from locomotion capability). Hardware quantities, integration, and tested behavior require separate source evidence.
The connectivity descriptions listed for the AI Sapiens K0 are Wi-Fi 5, Bluetooth 5.0, Ethernet (2×), USB 2.0 (2× USB-A), USB 3.0 (1× USB-C, 1× USB-A). Specific services and device interoperability require separate documentation.
Research robots are acquired by universities, government labs, and corporate R&D departments. They serve as experimental platforms for developing new algorithms, testing locomotion strategies, and advancing the field of robotics. Some are also used for educational purposes.
Open-source software compatibility (ROS/ROS 2), sensor modularity, programmability, available SDK/API quality, community support, and published research papers using the platform are key factors. Documentation quality and the ability to modify both hardware and software are essential for research use.
Listed pricing
The AI Sapiens K0 is listed as Development, indicating active development in the catalog. Specifications and release plans may change. Check ROBOTIS's current documentation for access options and release updates.
Recorded features and considerations to assess
The AI Sapiens K0 record lists 7 capabilities. Review their qualifiers and supporting evidence for the tasks you need. The number of entries does not establish workflow coverage, reliability, or the ability to replace other robots.
Not yet announced; Dynamixel-Q actuators scheduled for commercial release H2 2026
The AI Sapiens K0 is listed as Development, indicating active development in the catalog. Specifications and release plans may change. Check ROBOTIS's current documentation for access options and release updates.
Note: This strengths and trade-offs assessment is based on the AI Sapiens K0's documented specifications as tracked in the ui44 database. Real-world performance depends on deployment conditions, firmware maturity, and environmental factors. For the most current information, check the ROBOTIS manufacturer page or visit the official source. Use the comparison tool to evaluate these trade-offs against competing robots in the same category.
Understanding the engineering behind this category
Research robots serve a fundamentally different purpose than commercial or consumer models. They are platforms for discovery — enabling scientists and engineers to test theories, develop algorithms, and push the boundaries of what robots can do. The technology in research robots prioritizes openness, flexibility, and access to raw data over consumer-friendly packaging or commercial reliability. Understanding this distinction is important for anyone considering a research robot platform.
Research robots typically expose their navigation systems at a much lower level than commercial products. Researchers can access raw sensor data, modify SLAM algorithms, implement custom path planners, and test novel navigation approaches. ROS (Robot Operating System) and ROS 2 compatibility is standard, providing a common framework for sharing navigation modules across the research community. This openness enables rapid iteration — a researcher can swap between different SLAM implementations, test new obstacle avoidance strategies, or develop entirely novel navigation paradigms without being locked into a vendor's proprietary stack.
Research robots serve as physical testbeds for AI algorithms that may eventually appear in commercial products years later. Reinforcement learning, imitation learning, few-shot task learning, and human-robot interaction studies all require robot platforms that can execute AI-generated commands in the physical world. The gap between simulation (where training is cheap and fast) and reality (where physics is unforgiving) makes physical robot platforms essential for validating AI approaches. Research robots must support rapid deployment of new AI models without extensive integration work.
Research platforms prioritize sensor modularity and data access. Standard mounting interfaces allow researchers to attach custom sensors alongside built-in ones. Raw sensor data streams (not just processed results) are accessible for developing novel perception algorithms. Precise time-stamping and synchronization across sensor streams enable accurate multi-modal fusion research. Many research robots include more sensors than strictly necessary for any single application, providing researchers with rich datasets for developing and testing new algorithms.
Research robots balance operational runtime with practical lab use. Sessions of one to four hours are typical, with quick charging between experiments. Some research setups use tethered power for long-running experiments where battery limitations would interrupt data collection. Power monitoring and logging capabilities help researchers understand the energy costs of different behaviors and algorithms — important for developing efficient approaches that will eventually run on battery-constrained commercial systems.
Research environments present unique safety challenges because robots are constantly being programmed with untested behaviors. Hardware safety limits (joint speed caps, force limits, emergency stops) must be robust regardless of software commands. Safety-rated monitored stop and speed monitoring ensure the robot cannot exceed safe operating parameters even when running experimental code. Collaborative operation standards apply when researchers work alongside the robot during experiments. Many labs implement layered safety with physical barriers for high-speed testing and open-area operation restricted to validated, lower-risk behaviors.
Research robot platforms are becoming more accessible and capable. Cloud robotics enables remote experiment execution and shared datasets. Digital twins and high-fidelity simulators reduce the need for physical hardware time while improving sim-to-real transfer. Standardized benchmarks and open datasets enable fair comparison of results across labs. The democratization of robotics research — through lower-cost platforms, open-source software, and cloud infrastructure — is expanding who can contribute to advancing the field.
These are category-level technology examples; they do not establish the capabilities of the AI Sapiens K0. For its recorded hardware details, see the sensor analysis and connectivity sections above. Check model-specific documentation from ROBOTIS for supported behavior, or use the components glossary to look up terminology.
How this robot compares in the research landscape
Not yet announced; Dynamixel-Q actuators scheduled for commercial release H2 2026
The AI Sapiens K0 is listed as Development, indicating active development in the catalog. Specifications and release plans may change. Check ROBOTIS's current documentation for access options and release updates.
Side-by-side specs, capability overlap analysis, and key differentiators.
For the full picture of ROBOTIS's portfolio and market strategy, visit the ROBOTIS manufacturer page.
What the public profile tells you, and what still needs direct vendor confirmation
From a buying and rollout perspective, the AI Sapiens K0 should be read as a research platform aimed at labs and development teams validating robotics workflows. ui44 currently tracks 7 capability signals and a last verification date of 2026-04-24. That mix gives buyers a useful first-pass picture, but it is still only the public layer of due diligence, especially when procurement, uptime, and support commitments are decided directly with ROBOTIS.
Commercial model
See pricing details
Not yet announced; Dynamixel-Q actuators scheduled for commercial release H2 2026
Integration posture
5 connectivity options
The profile lists Wi-Fi 5, Bluetooth 5.0, Ethernet (2×), USB 2.0 (2× USB-A), USB 3.0 (1× USB-C, 1× USB-A). These labels do not establish APIs, fleet-management features, or workflow integration. These are the platforms, communities, or ecosystem relationships listed in the profile. A listed name or protocol alone does not confirm home-device interoperability or automation support.Recorded AI description: 6 TOPS NPU (int4/int8/int16/FP16/BF16/TF32), Cortex-A76×4 + Cortex-A55×4 CPU, Mali-G610 GPU; NVIDIA Isaac Sim for RL training, imitation learning via leader-follower system
Spec disclosure
4/7 core specs public
ui44 currently has 4 of 7 core physical and operating specs filled in for this model, leaving 3 gaps that matter for deployment planning. Missing runtime, charge, speed, or payload details can materially change staffing and site-readiness assumptions.
The current profile is useful for scouting, but it still leaves meaningful operational unknowns. If this robot is heading toward a pilot or purchase discussion, the next step should be a structured vendor Q&A that fills the remaining runtime, charging, payload, safety, or integration blanks before anyone builds ROI assumptions around it.
If you want a faster apples-to-apples read, compare the AI Sapiens K0 against nearby alternatives in ui44's compare view, then cross-check the underlying AI, sensor, and subsystem terms in the components glossary. For manufacturer-level context, the ROBOTIS profile helps anchor this robot inside the wider product lineup.
Practical guide from day one through years of ownership
Research robot setup combines hardware assembly with software environment configuration. Unpack and assemble the platform following the manufacturer's documentation. Install the development framework — typically ROS or ROS 2 — and verify sensor connectivity. Calibrate all sensors using the manufacturer's tools and procedures. Set up the simulation environment (Gazebo, Isaac Sim, or equivalent) alongside the physical platform for parallel development. Establish version control for your experiment code and configuration. Document the initial calibration values and system state as your baseline for future reference. Plan network and computing infrastructure to handle the data rates your sensors will generate.
Research robots need maintenance that preserves the precision required for valid experimental results. Regularly verify sensor calibration — drift in camera intrinsics or IMU biases can invalidate experiment data. Maintain clean workspace conditions to protect optical sensors. Document any hardware modifications or maintenance performed, as these can affect experimental reproducibility. Update software dependencies carefully, documenting versions used for each experiment. Joint and actuator wear in research robots that perform repetitive tasks should be monitored and factored into experimental design.
Research robot software updates require careful management to maintain experiment reproducibility. Document the exact software versions used for each experiment. Test updates in a separate environment before applying to your experiment platform. Contribute bug fixes and improvements back to the community when using open-source frameworks. Be aware that ROS and other framework updates may require code changes in your custom packages — budget time for integration testing after major framework updates.
Research robots often have longer productive lives than commercial products because they can be upgraded and repurposed. Extend your investment by maintaining clean mechanical and electrical systems, documenting all modifications for future lab members, and keeping spare parts for common wear items. When specific components become obsolete, community forums and lab networks can be valuable sources for replacements. Consider the platform's modularity when planning future research directions — a platform that can accept new sensors and actuators adapts to evolving research questions.
Find product and source links on the ROBOTIS page on ui44 or open ROBOTIS's official source. Use model-specific manufacturer documentation for setup, cleaning, and service instructions.
The AI Sapiens K0 record brings together the listed specifications and attributed claims. Consult the model description and source notes to distinguish manufacturer announcements, reported information, and unknowns. A source link or review date does not establish independent testing or manufacturer confirmation of every claim. Record last checked: 2026-04-24. Official source: ROBOTIS official source. If you find outdated or incorrect information, please let us know — accuracy is our top priority.
See how the AI Sapiens K0 stacks up — compare specs, browse the research category, or search the full database.