Commercial model
See pricing details
Public MSRP not disclosed; DEEP Robotics positions the Lynx S10 as a competitively priced small wheeled-legged industrial robot and directs buyers to contact sales.
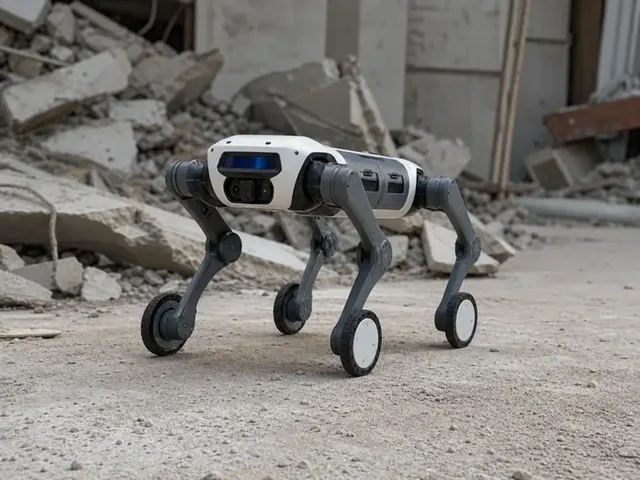
Weight
20 kg
Battery
More than 3 hours reported by launch coverage; not listed on the official product page
Speed
8 m/s
The Lynx S10 is DEEPRobotics' compact industry-grade wheeled-legged quadruped for lightweight inspection, patrol, emergency response, education, research, and outdoor exploration tasks. Official materials describe a sub-20 kg robot with wheeled-leg locomotion, AI gait control, autonomous mapping and path planning, intelligent obstacle avoidance, and an omnidirectional perception stack using ultra-wide-angle cameras plus front and rear LiDAR. It reaches up to 8 m/s on flat ground, can clear obstacles up to 50 cm, and is rated IP66 for dusty, wet, and outdoor operating environments from -20°C to 55°C. DEEP Robotics has not published public pricing, full dimensions, charging time, or an official payload spec.
Listed price
See pricing details
Public MSRP not disclosed; DEEP Robotics positions the Lynx S10 as a competitively priced small wheeled-legged industrial robot and directs buyers to contact sales.
Release window
May 22, 2026
Current status
Active
DEEPRobotics
Last verified
May 31, 2026
Share this robot
Open a plain share composer on X or Bluesky for this robot profile.
Technical overview
A fast read on the mechanical profile, sensing package, and listed platform details for Lynx S10.
Height
Not publicly disclosed
Weight
20 kg
Battery Life
More than 3 hours reported by launch coverage; not listed on the official product page
Charging Time
Not publicly disclosed
Max Speed
8 m/s
Payload
Not officially disclosed
Operational profile
Capabilities
11
Connectivity
0
Key capabilities
Certifications
Explore further
Benchmark set
Shortcuts to the closest alternatives in the current ui44 set.
Quadruped
LYNX M20
DEEPRobotics
See pricing details
Quadruped
X30
DEEPRobotics
See pricing details
Quadruped
D2 Max
AGIBOT
See pricing details
Quadruped
Lynx Sport
DEEPRobotics
$17,999
The Lynx S10 is a Quadruped robot built by DEEPRobotics. The Lynx S10 is DEEPRobotics' compact industry-grade wheeled-legged quadruped for lightweight inspection, patrol, emergency response, education, research, and outdoor exploration tasks. Official materials describe a sub-20 kg robot with wheeled-leg locomotion, AI gait control, autonomous mapping and path planning, intelligent obstacle avoidance, and an omnidirectional perception stack using ultra-wide-angle cameras plus front and rear LiDAR. It reaches up to 8 m/s on flat ground, can clear obstacles up to 50 cm, and is rated IP66 for dusty, wet, and outdoor operating environments from -20°C to 55°C. DEEP Robotics has not published public pricing, full dimensions, charging time, or an official payload spec.
Public MSRP not disclosed; DEEP Robotics positions the Lynx S10 as a competitively priced small wheeled-legged industrial robot and directs buyers to contact sales. See all DEEPRobotics robots on the DEEPRobotics page.
Detailed specifications for the Lynx S10
Weight
20 kg or less including batteryThe listed weight is 20 kg or less including battery. Weight alone does not establish locomotion, stability or safety around people. Check handling requirements and the model’s documented operating limits.
Battery Life
More than 3 hours reported by launch coverage; not listed on the official product pageThis is the recorded runtime entry. Test conditions and independent verification are not established by this field. Confirm workload, operating mode and environmental conditions before comparing runtimes.
Maximum Speed
8 m/sThe recorded maximum-speed entry is 8 m/s. It does not establish sustained travel speed, terrain handling, or safe speed around people. Check the source's gait, operating mode, surface and load conditions before planning movement through a shared space.
Read this recorded AI entry alongside the model description and source notes for announcement or deployment context. A platform name alone does not establish implemented features, autonomy, or performance.
The profile lists the sensor descriptions below. These entries do not establish physical sensor counts, sensor fusion, redundancy, or performance.
Consult the linked profile sources for hardware configuration and tested behavior. A technology label alone does not verify an operating capability.
Explore sensor technologies: components glossary · full components directory
Four-legged robots excel in environments where wheeled robots struggle — stairs, rough terrain, construction sites, and industrial facilities. Their biological-inspired locomotion provides stability and adaptability that makes them versatile platforms for a wide range of applications.
The Lynx S10 record lists 11 capabilities. Keep any announcement or demonstration qualifiers attached to these entries; the count alone does not establish practical performance.
These are the capabilities listed in the profile. Hardware configuration and demonstrated performance should be checked against the linked sources.
Compatibility and ecosystem details are not specified in the available profile.
11
Capabilities
AI
AI motion-control gait…
The Lynx S10 by DEEPRobotics has the following technology descriptions in its profile. The physical platform features a weight of 20 kg or less including battery, a top speed of 8 m/s, providing the foundation on which this technology stack operates.
The profile lists Four-direction ultra-wide-angle HDR cameras, Front LiDAR, Rear LiDAR, Hardware-level synchronized multi-sensor architecture. Hardware quantities, integration, and tested behavior require separate source evidence.
Quadruped robots are primarily purchased by industrial and enterprise customers for inspection, patrol, and data collection in environments too dangerous or tedious for humans. Some companion-oriented quadrupeds target tech-savvy consumers.
Terrain adaptability, payload capacity for sensor payloads, runtime per charge, IP rating for outdoor/industrial use, and autonomous navigation in unstructured environments are key factors. For industrial use, consider integration with existing asset management and inspection workflows.
Listed pricing
The Lynx S10 is listed as Active. This status alone does not confirm public purchase availability or operational reliability. Contact DEEPRobotics for current access options and any purchase or participation requirements.
Recorded features and considerations to assess
The Lynx S10 record lists 11 capabilities. Review their qualifiers and supporting evidence for the tasks you need. The number of entries does not establish workflow coverage, reliability, or the ability to replace other robots.
The battery-life entry is More than 3 hours reported by launch coverage; not listed on the official product page. Check the source conditions and operating mode before using this figure to plan a session. It does not establish task completion, area coverage, or continuous-use runtime.
The speed entry is 8 m/s. Preserve its gait, mode, and comparison qualifiers when comparing models. This figure alone does not establish agility, response time, terrain handling, or safe speed around people.
Public MSRP not disclosed; DEEP Robotics positions the Lynx S10 as a competitively priced small wheeled-legged industrial robot and directs buyers to contact sales.
Compatibility and ecosystem details are not specified in the profile for the Lynx S10. Confirm supported platforms, device-control functions, and deployment requirements in product documentation before relying on an integration.
Note: This strengths and trade-offs assessment is based on the Lynx S10's documented specifications as tracked in the ui44 database. Real-world performance depends on deployment conditions, firmware maturity, and environmental factors. For the most current information, check the DEEPRobotics manufacturer page or visit the official source. Use the comparison tool to evaluate these trade-offs against competing robots in the same category.
Understanding the engineering behind this category
Four-legged robots represent a biomimetic approach to mobility — taking inspiration from nature's most versatile terrestrial locomotion strategy. Unlike wheeled or tracked robots, quadrupeds can navigate stairs, step over obstacles, traverse rough terrain, and recover from stumbles. The engineering behind these machines combines advanced control theory, real-time computation, and rugged mechanical design into platforms that go where other robots simply cannot.
Quadruped navigation combines classical SLAM with proprioceptive terrain sensing. The robot builds environment maps using LiDAR and cameras while simultaneously using force sensors in its feet and joint torque measurements to understand ground conditions beneath each footstep. This dual approach — seeing ahead while feeling underfoot — enables navigation through environments that would confuse purely vision-based systems, like muddy terrain or surfaces covered in snow. Path planning for legged robots is more complex than for wheeled platforms because the planner must consider foothold locations, body clearance, and dynamic stability at every step.
AI in quadruped robots increasingly relies on learned locomotion policies trained in simulation and transferred to real hardware. Rather than hand-coding gait controllers for every terrain type, modern systems use reinforcement learning to develop robust walking behaviors that generalize across surfaces. This sim-to-real approach has dramatically improved quadruped agility and robustness. Higher-level AI handles mission planning, autonomous inspection routines, anomaly detection, and integration with enterprise software systems for industrial applications.
Quadruped robots carry sophisticated sensor payloads combining environmental perception with proprioceptive awareness. Outward-facing sensors (LiDAR, cameras, depth sensors) map the environment and identify obstacles. Inward-facing sensors (joint encoders, IMUs, force/torque sensors) monitor the robot's own state — its balance, footing, and body orientation. The fusion of external and internal sensing is uniquely important for legged robots because stable locomotion requires constant feedback about both where the robot is going and how its body is responding to each step. Payload-mounted inspection sensors (thermal cameras, gas detectors, acoustic sensors) add application-specific perception on top of the mobility platform.
Legged locomotion is energy-intensive, and battery life is a critical constraint for quadruped robots. Most commercial quadrupeds offer one to two hours of active operation per charge. Power consumption varies significantly with gait speed, terrain difficulty, and payload weight. Battery-swap systems are common in industrial deployments, allowing continuous operation through multiple battery packs. Some facilities install automatic charging stations where the robot can dock and recharge between patrol routes. Efficient gait selection — using the least energy-consuming walking pattern appropriate for current terrain — is an active optimization area.
Quadruped robots operating in industrial and public environments must handle safety across multiple dimensions. Physical safety features include compliant leg designs that absorb unexpected impacts, emergency stop buttons, and speed-limiting zones around detected humans. Autonomous safety behaviors include automatic sit-down when battery reaches critical levels, return-to-base when communication is lost, and avoidance of detected hazards. For outdoor operation, IP ratings (typically IP54 or higher) ensure resistance to dust and water. Operational geofencing ensures the robot stays within approved areas.
Quadruped robotics is moving toward greater autonomy, longer endurance, and expanded manipulation capability. The addition of robotic arms to quadruped platforms is creating mobile manipulation systems that can not only inspect but also interact with the environment — turning valves, pressing buttons, or collecting samples. Improved batteries and more efficient actuators are extending operational windows. Fleet coordination of multiple quadrupeds for large-area coverage is becoming practical. As costs decrease, quadruped robots are expanding from premium industrial inspection tools into more accessible commercial and even consumer applications.
These are category-level technology examples; they do not establish the capabilities of the Lynx S10. For its recorded hardware details, see the sensor analysis and connectivity sections above. Check model-specific documentation from DEEPRobotics for supported behavior, or use the components glossary to look up terminology.
How this robot compares in the quadruped landscape
Public MSRP not disclosed; DEEP Robotics positions the Lynx S10 as a competitively priced small wheeled-legged industrial robot and directs buyers to contact sales.
The Lynx S10 is listed as Active. This status alone does not confirm public purchase availability or operational reliability. Contact DEEPRobotics for current access options and any purchase or participation requirements.
Side-by-side specs, capability overlap analysis, and key differentiators.
For the full picture of DEEPRobotics's portfolio and market strategy, visit the DEEPRobotics manufacturer page.
What the public profile tells you, and what still needs direct vendor confirmation
From a buying and rollout perspective, the Lynx S10 should be read as a quadruped platform aimed at inspection routes and terrain that challenge wheeled platforms. ui44 currently tracks 11 capability signals and a last verification date of 2026-05-31. That mix gives buyers a useful first-pass picture, but it is still only the public layer of due diligence, especially when procurement, uptime, and support commitments are decided directly with DEEPRobotics.
Commercial model
See pricing details
Public MSRP not disclosed; DEEP Robotics positions the Lynx S10 as a competitively priced small wheeled-legged industrial robot and directs buyers to contact sales.
Integration posture
Integration details thin
The page does not list any connectivity standards, so procurement teams should verify network requirements, remote management options, and how the robot fits into existing software or facility infrastructure.Recorded AI description: AI motion-control gait algorithm with autonomous mapping, localization, path planning, and intelligent obstacle avoidance.
Spec disclosure
3/7 core specs public
ui44 currently has 3 of 7 core physical and operating specs filled in for this model, leaving 4 gaps that matter for deployment planning. Missing runtime, charge, speed, or payload details can materially change staffing and site-readiness assumptions.
The current profile is useful for scouting, but it still leaves meaningful operational unknowns. If this robot is heading toward a pilot or purchase discussion, the next step should be a structured vendor Q&A that fills the remaining runtime, charging, payload, safety, or integration blanks before anyone builds ROI assumptions around it.
If you want a faster apples-to-apples read, compare the Lynx S10 against nearby alternatives in ui44's compare view, then cross-check the underlying AI, sensor, and subsystem terms in the components glossary. For manufacturer-level context, the DEEPRobotics profile helps anchor this robot inside the wider product lineup.
Practical guide from day one through years of ownership
Quadruped robot setup typically involves professional installation or detailed guided procedures. Initial steps include unpacking and physical inspection, charging the battery fully before first use, installing any payload accessories (sensors, cameras, manipulators), connecting to the control network, running joint calibration and self-test routines, and mapping the initial operating environment. Industrial deployments may require integration with facility networks, security systems, and asset management platforms. Plan for a multi-day setup process for enterprise installations, including operator training and safety protocol establishment.
Quadruped robots require more frequent maintenance than wheeled platforms due to the mechanical complexity of their legs. Weekly checks should include joint inspection for unusual sounds or play, foot pad condition assessment, sensor cleaning, and battery health verification. Monthly maintenance includes more thorough mechanical inspection, firmware updates, and locomotion performance benchmarking. Legs and joints are the primary wear points — monitor for vibration changes that might indicate bearing wear or actuator degradation. Keep a detailed maintenance log, as patterns in the data can predict component failures before they cause operational disruption.
Quadruped robot software updates can significantly improve locomotion performance, autonomous navigation capability, and mission execution efficiency. Gait improvements based on real-world deployment data can make the robot faster, more stable, and more energy-efficient. Security patches are particularly important for robots operating in sensitive industrial or commercial environments. Coordinate updates with your deployment schedule to avoid disruption, and test updates in a controlled area before returning the robot to active duty.
Maximizing the service life of a quadruped robot requires attention to both mechanical and environmental factors. Operate within specified payload limits to avoid accelerated joint wear. Use appropriate gaits for the terrain — running on flat floors when a walk would suffice wastes energy and increases mechanical stress. Keep the robot's IP-rated seals in good condition for outdoor operation. Battery care is critical: follow the manufacturer's charging guidelines, avoid deep discharges, and replace batteries when capacity drops below 80% of original. A service contract with the manufacturer ensures access to replacement parts and expert maintenance that can keep the robot operational for many years.
Find product and source links on the DEEPRobotics page on ui44 or open DEEPRobotics's official source. Use model-specific manufacturer documentation for setup, cleaning, and service instructions.
The Lynx S10 record brings together the listed specifications and attributed claims. Consult the model description and source notes to distinguish manufacturer announcements, reported information, and unknowns. A source link or review date does not establish independent testing or manufacturer confirmation of every claim. Record last checked: 2026-05-31. Official source: DEEPRobotics official source. If you find outdated or incorrect information, please let us know — accuracy is our top priority.
See how the Lynx S10 stacks up — compare specs, browse the quadruped category, or search the full database.