Commercial model
See pricing details
No public standalone robot pricing announced; All3 presents Mantis as part of its integrated construction technology and general-contractor delivery model.
Payload
100 kg
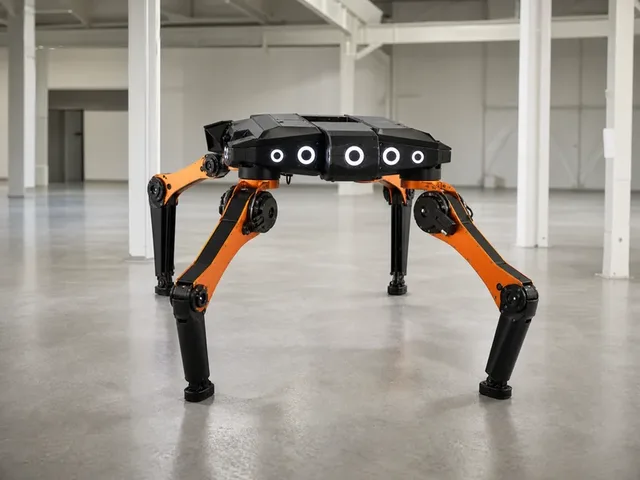
Mantis is All3's four-legged autonomous construction robot for on-site assembly, designed for All3's vertically integrated building process rather than standalone consumer sales. Official materials describe a fully electric, modular platform with embodied AI trained on All3's building logic, reconfigurable tools, adaptive leg stance for doorways and tight zones, and swappable payload/tool modules for placing, fastening, finishing, drilling, and inspecting building elements. All3 lists 100 kg+ payload capacity, a 4 m telescopic reach, millimetre-level placement accuracy with plug-and-play connectors and positioners, and indoor/outdoor operation across uneven surfaces, stairs, and multi-storey interiors. May 2026 coverage of All3's $25 million seed round reported plans to deploy robot fleets on first commercial construction projects in Germany in 2026-2027; public sale pricing and many hardware specifications have not been disclosed.
Listed price
See pricing details
No public standalone robot pricing announced; All3 presents Mantis as part of its integrated construction technology and general-contractor delivery model.
Release window
Jun 19, 2025
Current status
Development
All3
Last verified
Jun 7, 2026
Share this robot
Open a plain share composer on X or Bluesky for this robot profile.
Technical overview
A fast read on the mechanical profile, sensing package, and listed platform details for Mantis.
Height
Not publicly disclosed
Weight
Not publicly disclosed
Dimensions
4 m
Battery Life
Not publicly disclosed
Charging Time
Not publicly disclosed
Max Speed
Not publicly disclosed
Payload
100 kg
Operational profile
Capabilities
12
Connectivity
1
Key capabilities
Listed platforms & ecosystem
Explore further
Benchmark set
Shortcuts to the closest alternatives in the current ui44 set.
Quadruped
Hypertron-T01
Astrall Dynamics
See pricing details
Quadruped
CyberDog 2
Xiaomi
See pricing details
Quadruped
D2 Max
AGIBOT
See pricing details
Quadruped
Argos X1
AiMOGA Robotics
¥15,800
The Mantis is a Quadruped robot built by All3. Mantis is All3's four-legged autonomous construction robot for on-site assembly, designed for All3's vertically integrated building process rather than standalone consumer sales. Official materials describe a fully electric, modular platform with embodied AI trained on All3's building logic, reconfigurable tools, adaptive leg stance for doorways and tight zones, and swappable payload/tool modules for placing, fastening, finishing, drilling, and inspecting building elements. All3 lists 100 kg+ payload capacity, a 4 m telescopic reach, millimetre-level placement accuracy with plug-and-play connectors and positioners, and indoor/outdoor operation across uneven surfaces, stairs, and multi-storey interiors. May 2026 coverage of All3's $25 million seed round reported plans to deploy robot fleets on first commercial construction projects in Germany in 2026-2027; public sale pricing and many hardware specifications have not been disclosed.
No public standalone robot pricing announced; All3 presents Mantis as part of its integrated construction technology and general-contractor delivery model. See all All3 robots on the All3 page.
Detailed specifications for the Mantis
Dimensions
4 m telescopic reachThe overall dimensions of 4 m telescopic reach are a recorded size entry. Check which axes and configuration it covers: a height-only entry does not establish width, depth or passage fit. Planning clearance also requires the operating envelope, turning space, attachments and documented margins.
Payload Capacity
100 kg+The recorded payload entry is 100 kg+. A load figure alone does not establish which objects the robot can grasp, lift or carry. Confirm whether the limit applies to one arm, two arms or a mounted load, and check reach, posture and motion conditions in model-specific documentation.
Read this recorded AI entry alongside the model description and source notes for announcement or deployment context. A platform name alone does not establish implemented features, autonomy, or performance.
The profile lists the sensor descriptions below. These entries do not establish physical sensor counts, sensor fusion, redundancy, or performance.
Consult the linked profile sources for hardware configuration and tested behavior. A technology label alone does not verify an operating capability.
Explore sensor technologies: components glossary · full components directory
Four-legged robots excel in environments where wheeled robots struggle — stairs, rough terrain, construction sites, and industrial facilities. Their biological-inspired locomotion provides stability and adaptability that makes them versatile platforms for a wide range of applications.
The Mantis record lists 12 capabilities. Keep any announcement or demonstration qualifiers attached to these entries; the count alone does not establish practical performance.
These are the capabilities listed in the profile. Hardware configuration and demonstrated performance should be checked against the linked sources.
These are the platforms, communities, or ecosystem relationships listed in the profile. A listed name or protocol alone does not confirm home-device interoperability or automation support.
12
Capabilities
AI
Embodied AI trained on…
The Mantis profile lists the following communication and voice-system descriptions.
The Mantis by All3 has the following technology descriptions in its profile.
The profile lists Site-awareness sensor stack not publicly detailed, Plug-and-play connector and positioner alignment system. Hardware quantities, integration, and tested behavior require separate source evidence.
The connectivity descriptions listed for the Mantis are Not publicly disclosed. Specific services and device interoperability require separate documentation.
Quadruped robots are primarily purchased by industrial and enterprise customers for inspection, patrol, and data collection in environments too dangerous or tedious for humans. Some companion-oriented quadrupeds target tech-savvy consumers.
Terrain adaptability, payload capacity for sensor payloads, runtime per charge, IP rating for outdoor/industrial use, and autonomous navigation in unstructured environments are key factors. For industrial use, consider integration with existing asset management and inspection workflows.
Listed pricing
The Mantis is listed as Development, indicating active development in the catalog. Specifications and release plans may change. Check All3's current documentation for access options and release updates.
Recorded features and considerations to assess
The Mantis record lists 12 capabilities. Review their qualifiers and supporting evidence for the tasks you need. The number of entries does not establish workflow coverage, reliability, or the ability to replace other robots.
The payload entry is 100 kg+. This figure alone does not establish grasping, carrying, tool use or equipment-mount compatibility. Confirm the manufacturer's load envelope, attachment requirements and operating conditions for the proposed task.
No public standalone robot pricing announced; All3 presents Mantis as part of its integrated construction technology and general-contractor delivery model.
The Mantis is listed as Development, indicating active development in the catalog. Specifications and release plans may change. Check All3's current documentation for access options and release updates.
Note: This strengths and trade-offs assessment is based on the Mantis's documented specifications as tracked in the ui44 database. Real-world performance depends on deployment conditions, firmware maturity, and environmental factors. For the most current information, check the All3 manufacturer page or visit the official source. Use the comparison tool to evaluate these trade-offs against competing robots in the same category.
Understanding the engineering behind this category
Four-legged robots represent a biomimetic approach to mobility — taking inspiration from nature's most versatile terrestrial locomotion strategy. Unlike wheeled or tracked robots, quadrupeds can navigate stairs, step over obstacles, traverse rough terrain, and recover from stumbles. The engineering behind these machines combines advanced control theory, real-time computation, and rugged mechanical design into platforms that go where other robots simply cannot.
Quadruped navigation combines classical SLAM with proprioceptive terrain sensing. The robot builds environment maps using LiDAR and cameras while simultaneously using force sensors in its feet and joint torque measurements to understand ground conditions beneath each footstep. This dual approach — seeing ahead while feeling underfoot — enables navigation through environments that would confuse purely vision-based systems, like muddy terrain or surfaces covered in snow. Path planning for legged robots is more complex than for wheeled platforms because the planner must consider foothold locations, body clearance, and dynamic stability at every step.
AI in quadruped robots increasingly relies on learned locomotion policies trained in simulation and transferred to real hardware. Rather than hand-coding gait controllers for every terrain type, modern systems use reinforcement learning to develop robust walking behaviors that generalize across surfaces. This sim-to-real approach has dramatically improved quadruped agility and robustness. Higher-level AI handles mission planning, autonomous inspection routines, anomaly detection, and integration with enterprise software systems for industrial applications.
Quadruped robots carry sophisticated sensor payloads combining environmental perception with proprioceptive awareness. Outward-facing sensors (LiDAR, cameras, depth sensors) map the environment and identify obstacles. Inward-facing sensors (joint encoders, IMUs, force/torque sensors) monitor the robot's own state — its balance, footing, and body orientation. The fusion of external and internal sensing is uniquely important for legged robots because stable locomotion requires constant feedback about both where the robot is going and how its body is responding to each step. Payload-mounted inspection sensors (thermal cameras, gas detectors, acoustic sensors) add application-specific perception on top of the mobility platform.
Legged locomotion is energy-intensive, and battery life is a critical constraint for quadruped robots. Most commercial quadrupeds offer one to two hours of active operation per charge. Power consumption varies significantly with gait speed, terrain difficulty, and payload weight. Battery-swap systems are common in industrial deployments, allowing continuous operation through multiple battery packs. Some facilities install automatic charging stations where the robot can dock and recharge between patrol routes. Efficient gait selection — using the least energy-consuming walking pattern appropriate for current terrain — is an active optimization area.
Quadruped robots operating in industrial and public environments must handle safety across multiple dimensions. Physical safety features include compliant leg designs that absorb unexpected impacts, emergency stop buttons, and speed-limiting zones around detected humans. Autonomous safety behaviors include automatic sit-down when battery reaches critical levels, return-to-base when communication is lost, and avoidance of detected hazards. For outdoor operation, IP ratings (typically IP54 or higher) ensure resistance to dust and water. Operational geofencing ensures the robot stays within approved areas.
Quadruped robotics is moving toward greater autonomy, longer endurance, and expanded manipulation capability. The addition of robotic arms to quadruped platforms is creating mobile manipulation systems that can not only inspect but also interact with the environment — turning valves, pressing buttons, or collecting samples. Improved batteries and more efficient actuators are extending operational windows. Fleet coordination of multiple quadrupeds for large-area coverage is becoming practical. As costs decrease, quadruped robots are expanding from premium industrial inspection tools into more accessible commercial and even consumer applications.
These are category-level technology examples; they do not establish the capabilities of the Mantis. For its recorded hardware details, see the sensor analysis and connectivity sections above. Check model-specific documentation from All3 for supported behavior, or use the components glossary to look up terminology.
How this robot compares in the quadruped landscape
No public standalone robot pricing announced; All3 presents Mantis as part of its integrated construction technology and general-contractor delivery model.
The Mantis is listed as Development, indicating active development in the catalog. Specifications and release plans may change. Check All3's current documentation for access options and release updates.
Side-by-side specs, capability overlap analysis, and key differentiators.
For the full picture of All3's portfolio and market strategy, visit the All3 manufacturer page.
What the public profile tells you, and what still needs direct vendor confirmation
From a buying and rollout perspective, the Mantis should be read as a quadruped platform aimed at inspection routes and terrain that challenge wheeled platforms. ui44 currently tracks 12 capability signals and a last verification date of 2026-06-07. That mix gives buyers a useful first-pass picture, but it is still only the public layer of due diligence, especially when procurement, uptime, and support commitments are decided directly with All3.
Commercial model
See pricing details
No public standalone robot pricing announced; All3 presents Mantis as part of its integrated construction technology and general-contractor delivery model.
Integration posture
1 connectivity option
The profile lists Not publicly disclosed. These labels do not establish APIs, fleet-management features, or workflow integration. These are the platforms, communities, or ecosystem relationships listed in the profile. A listed name or protocol alone does not confirm home-device interoperability or automation support.
Spec disclosure
2/7 core specs public
ui44 currently has 2 of 7 core physical and operating specs filled in for this model, leaving 5 gaps that matter for deployment planning. Missing runtime, charge, speed, or payload details can materially change staffing and site-readiness assumptions.
The current profile is useful for scouting, but it still leaves meaningful operational unknowns. If this robot is heading toward a pilot or purchase discussion, the next step should be a structured vendor Q&A that fills the remaining runtime, charging, payload, safety, or integration blanks before anyone builds ROI assumptions around it.
If you want a faster apples-to-apples read, compare the Mantis against nearby alternatives in ui44's compare view, then cross-check the underlying AI, sensor, and subsystem terms in the components glossary. For manufacturer-level context, the All3 profile helps anchor this robot inside the wider product lineup.
Practical guide from day one through years of ownership
Quadruped robot setup typically involves professional installation or detailed guided procedures. Initial steps include unpacking and physical inspection, charging the battery fully before first use, installing any payload accessories (sensors, cameras, manipulators), connecting to the control network, running joint calibration and self-test routines, and mapping the initial operating environment. Industrial deployments may require integration with facility networks, security systems, and asset management platforms. Plan for a multi-day setup process for enterprise installations, including operator training and safety protocol establishment.
Quadruped robots require more frequent maintenance than wheeled platforms due to the mechanical complexity of their legs. Weekly checks should include joint inspection for unusual sounds or play, foot pad condition assessment, sensor cleaning, and battery health verification. Monthly maintenance includes more thorough mechanical inspection, firmware updates, and locomotion performance benchmarking. Legs and joints are the primary wear points — monitor for vibration changes that might indicate bearing wear or actuator degradation. Keep a detailed maintenance log, as patterns in the data can predict component failures before they cause operational disruption.
Quadruped robot software updates can significantly improve locomotion performance, autonomous navigation capability, and mission execution efficiency. Gait improvements based on real-world deployment data can make the robot faster, more stable, and more energy-efficient. Security patches are particularly important for robots operating in sensitive industrial or commercial environments. Coordinate updates with your deployment schedule to avoid disruption, and test updates in a controlled area before returning the robot to active duty.
Maximizing the service life of a quadruped robot requires attention to both mechanical and environmental factors. Operate within specified payload limits to avoid accelerated joint wear. Use appropriate gaits for the terrain — running on flat floors when a walk would suffice wastes energy and increases mechanical stress. Keep the robot's IP-rated seals in good condition for outdoor operation. Battery care is critical: follow the manufacturer's charging guidelines, avoid deep discharges, and replace batteries when capacity drops below 80% of original. A service contract with the manufacturer ensures access to replacement parts and expert maintenance that can keep the robot operational for many years.
Find product and source links on the All3 page on ui44 or open All3's official source. Use model-specific manufacturer documentation for setup, cleaning, and service instructions.
The Mantis record brings together the listed specifications and attributed claims. Consult the model description and source notes to distinguish manufacturer announcements, reported information, and unknowns. A source link or review date does not establish independent testing or manufacturer confirmation of every claim. Record last checked: 2026-06-07. Official source: All3 official source. If you find outdated or incorrect information, please let us know — accuracy is our top priority.
See how the Mantis stacks up — compare specs, browse the quadruped category, or search the full database.